I am pursuing a Ph.D. degree in Control Science and Engineering at Harbin Engineering University. I am currently a jointly trained Ph.D. student in the School of Computer Science and Informatics at the University of Liverpool. I received my bachelor's degree from the College of Intelligent Systems Science and Engineering, Harbin Engineering University.

My recent research focuses on 3D scene representation and SLAM for multi-robot and embodied AI. I study how robots can build shared spatial memory by connecting geometric mapping, 3D Gaussian Splatting, semantic scene understanding, and foundation-model priors for navigation, manipulation, and collaboration.

I am recently visiting the Physical Intelligence Lab, in the Digital Innovation Facility at the University of Liverpool, working closely with Dr. Baoru Huang and Prof. Anh Nguyen.

I serve as a reviewer for journals including TPAMI, IJCV, TIP, TCSVT, T-RO, T-ASE, and TIM, and for conferences including CVPR, ICCV, ECCV, NeurIPS, ICLR, AAAI, ACM MM, ICRA, IROS, MICCAI, and ICASSP.

Education

University of Liverpool

2025 – 2027

Joint Ph.D. training, Computer Science and Informatics

Harbin Engineering University

2023 – 2028

Ph.D. in Control Science and Engineering

Harbin Engineering University

2019 – 2023

B.Eng. in Measurement and Control Technology

Interests

  • 3D Scene Representation for Robotics
  • Multi-Source Navigation and Fusion
  • Computer Vision for Intelligent Systems

News

  • [05/2026] Personal homepage online.
  • [08/2025] Started joint Ph.D. training in the School of Computer Science and Informatics, University of Liverpool.
  • [08/2023] Paper accepted by IEEE International Conference on Mechatronics and Automation (ICMA).

Representative Work

CoMo3R-SLAM outdoor multi-agent reconstruction

Preprint / arXiv, 2026 / Under review

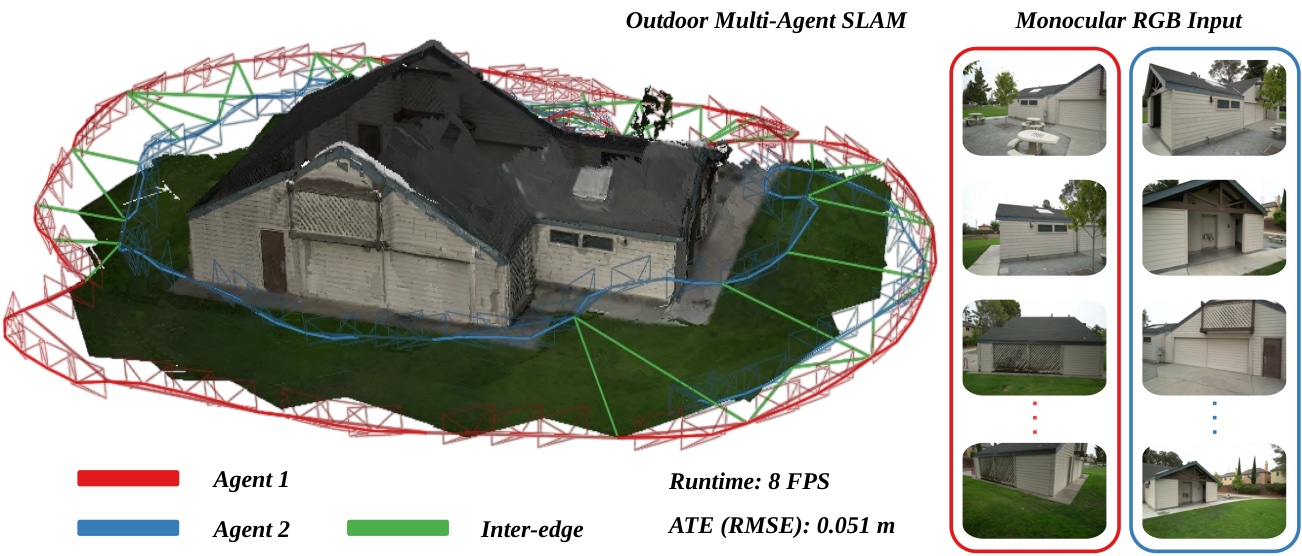
CoMo3R-SLAM: Collaborative Monocular Dense SLAM with Learned 3D Reconstruction Priors for Outdoor Multi-Agent Systems

Qi Shao*, Zhihao Cao*, Shuhao Zhai, Feng Tian, Anh Nguyen, Hesheng Wang, Baoru Huang

A collaborative monocular dense SLAM system that uses feed-forward 3D reconstruction priors to anchor scale across agents and verify inter-agent links, without depth sensors or known intrinsics.

MAGS-SLAM system overview

IEEE T-ASE, 2026 / Accepted

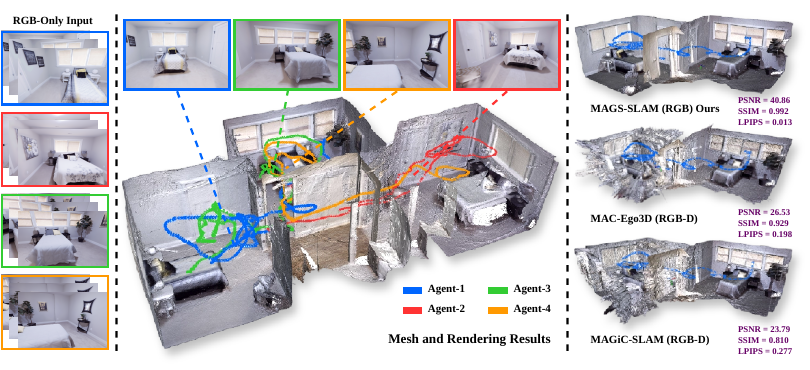
MAGS-SLAM: Monocular Multi-Agent Gaussian Splatting SLAM for Geometrically and Photometrically Consistent Reconstruction

Qi Shao*, Zhihao Cao*, Shuhao Zhai, Jing Zhang, Anh Nguyen, Hesheng Wang, Baoru Huang

An RGB-only multi-agent 3D Gaussian Splatting SLAM framework for collaborative scene reconstruction without active depth sensors.

DRMC-SLAM pipeline

2026 / Under review

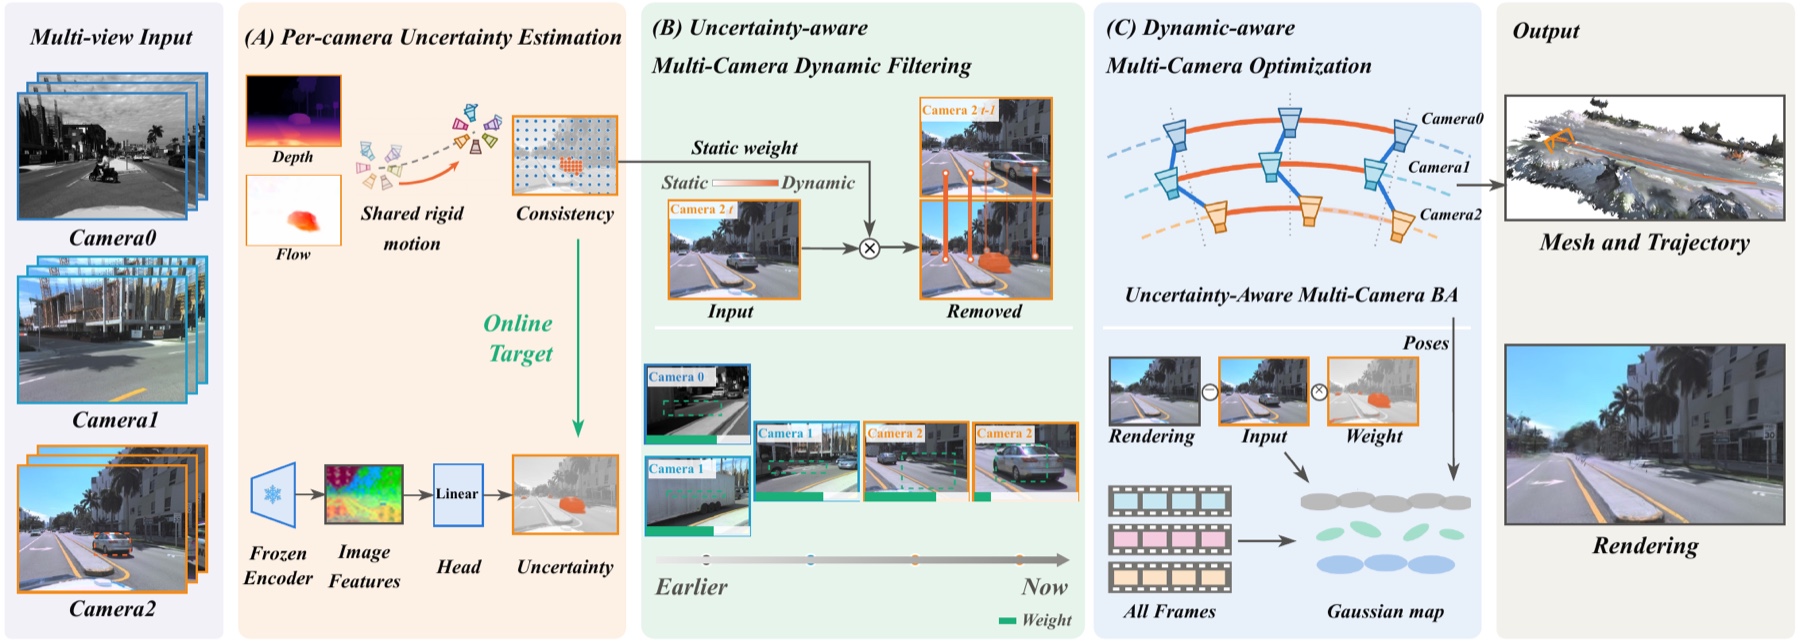
DRMC-SLAM: Dynamic-Robust Multi-Camera SLAM via Multi-View Geometric Consistency

Qi Shao*, Zhihao Cao*, Taoyu Wu, Shuhao Zhai, Anh Nguyen, Haoran Luo, Hong Liang, Baoru Huang

A dynamic-robust multi-camera Gaussian SLAM framework that uses the shared ego-motion of surround-view cameras to weight tracking and mapping against moving objects, and recovers occluded static regions from complementary views across cameras and time.

* Equal contribution.